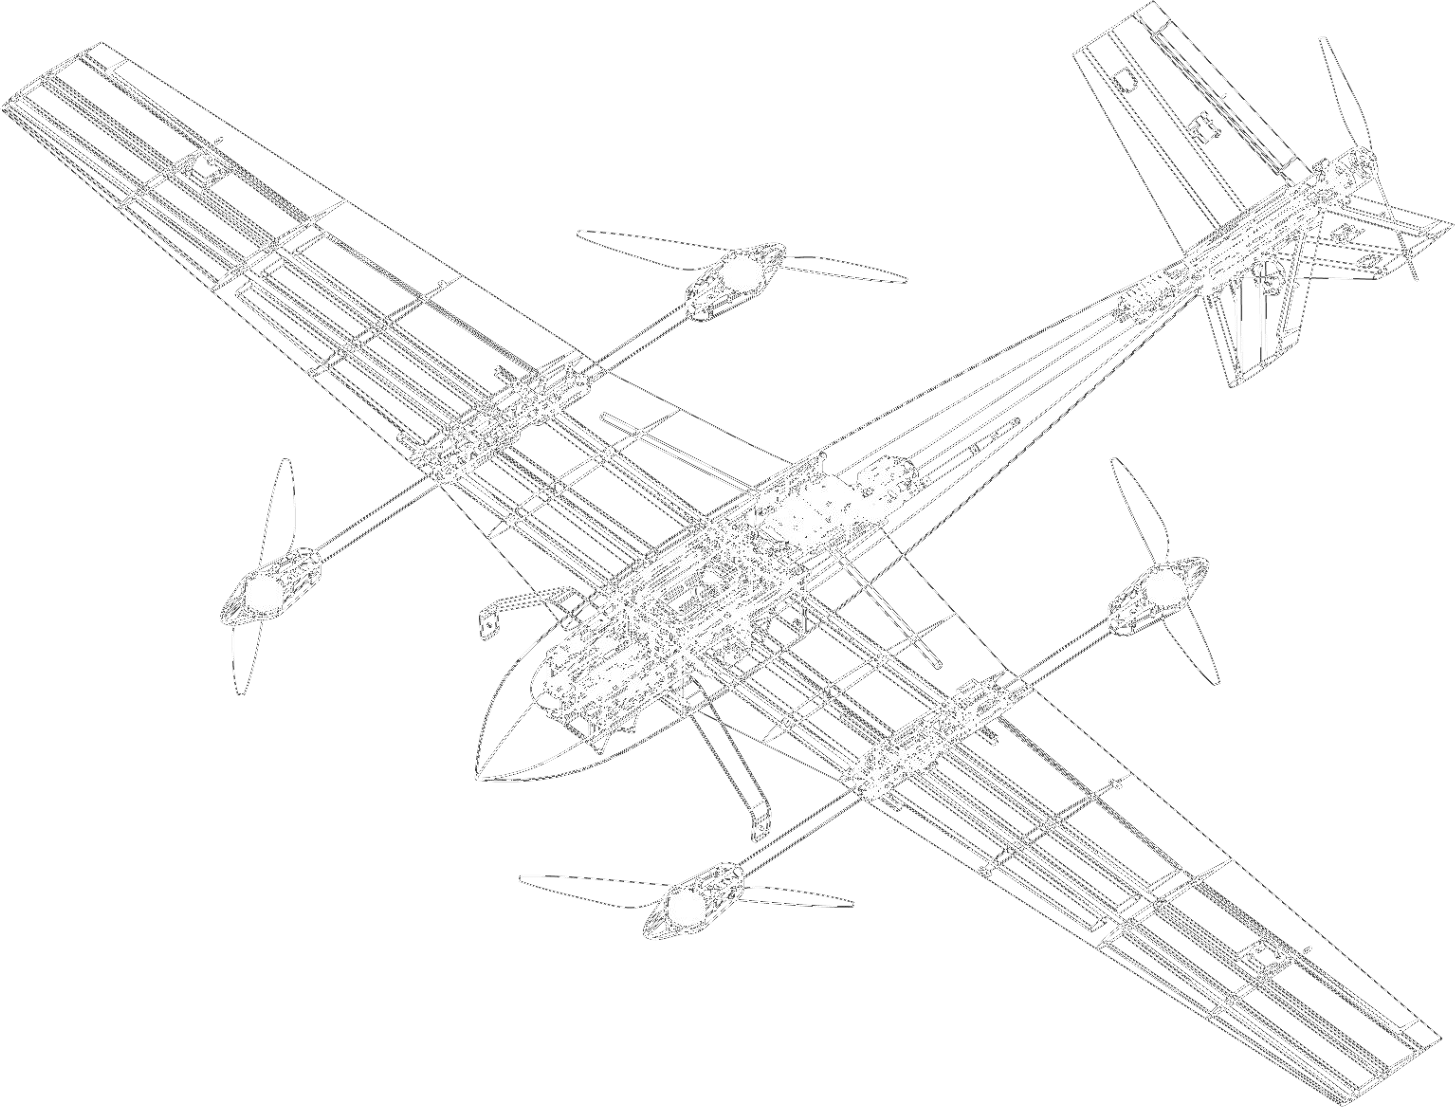
Four lift motors handle vertical flight. The rear motor provides thrust for the planned fixed-wing cruise mode.
SUAS 2025-2026 Competition Vehicle
MeadowHawk
We are building MeadowHawk, a five-motor QuadPlane for the 2026 SUAS Competition. It is designed to take off vertically, search an assigned area, and deliver relief payloads.
Proof flight - July 21, 2026 MeadowHawk flew six autonomous VTOL waypoint laps totaling more than one mile. Watch the video.
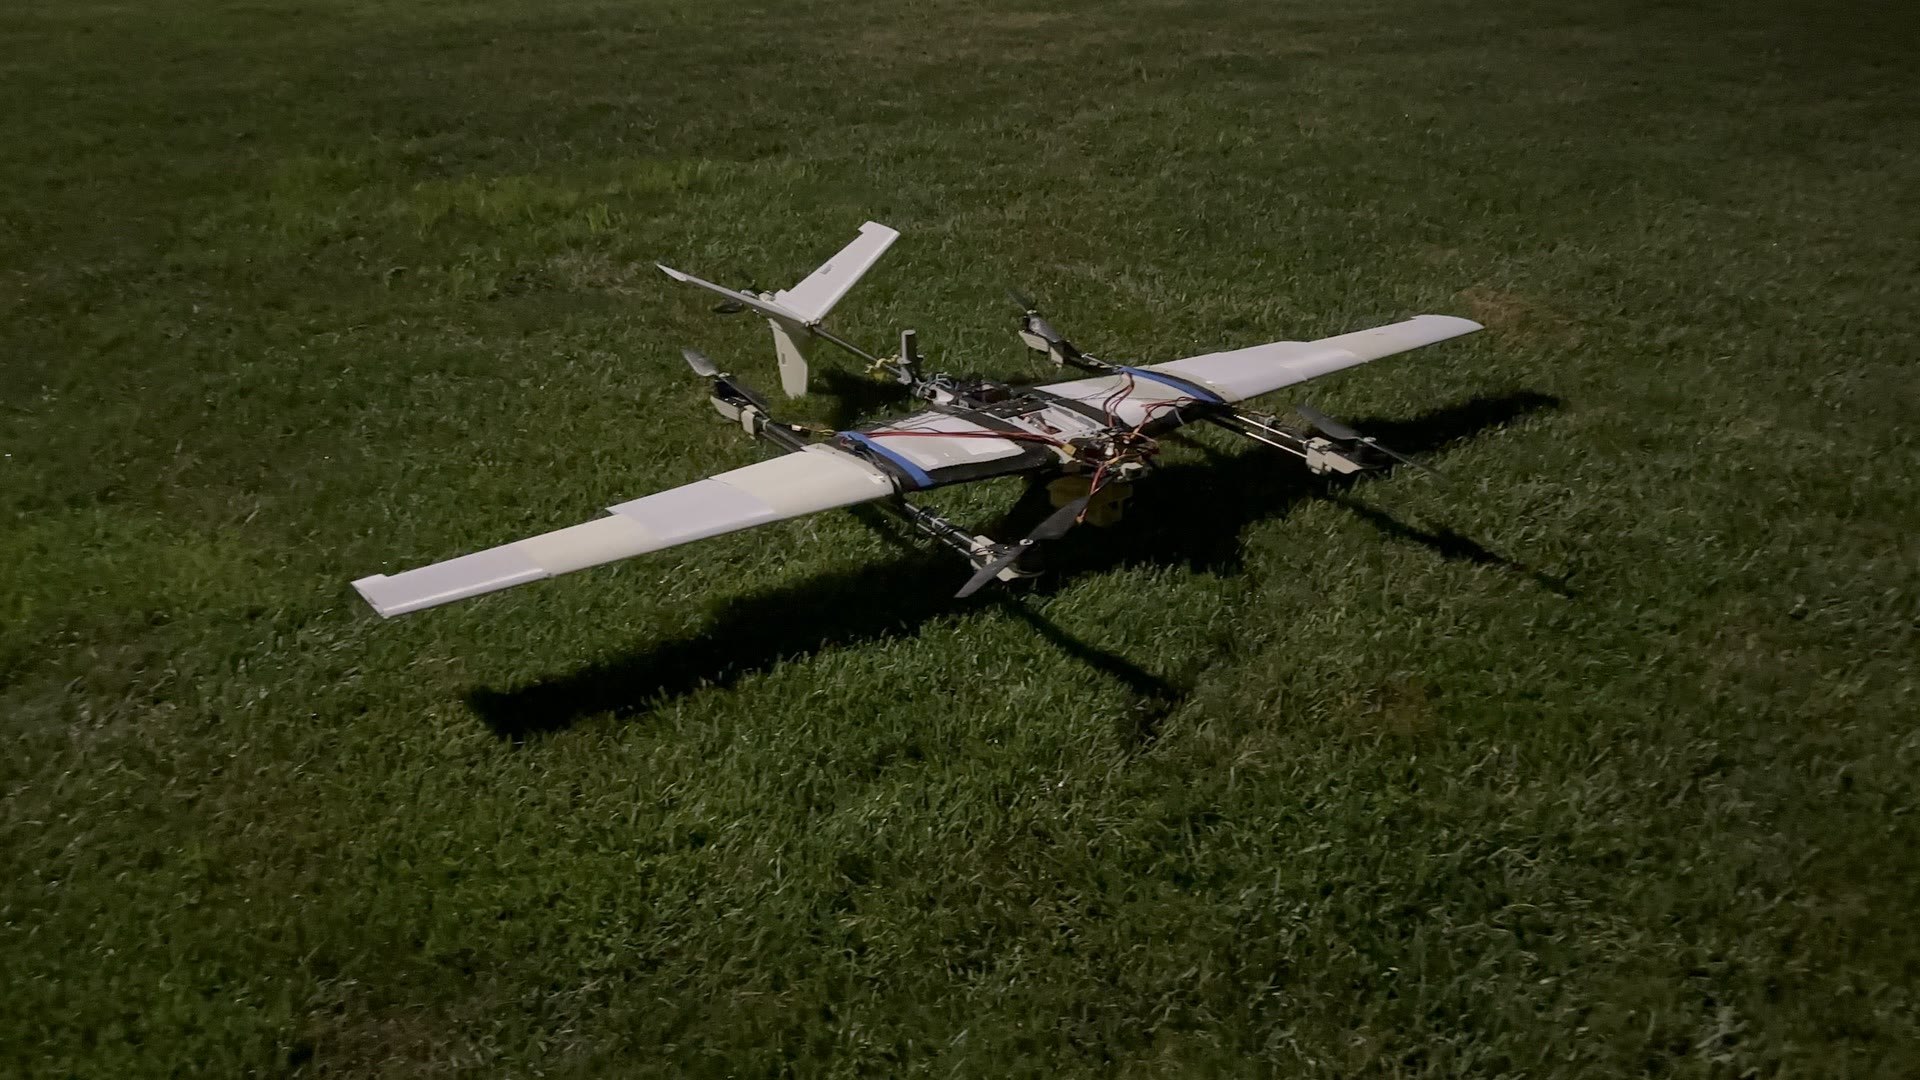
2025-2026 competition aircraft
MeadowHawk
A five-motor VTOL fixed-wing aircraft developed for the 2026 SUAS mission.
- Configuration
- Five-motor QuadPlane
- Proof flight
- July 21, 2026
- TDR design condition
- Approximately 19 lb
MeadowHawk is named for the red meadowhawk dragonfly, a species found across the Midwest. Its red color also connects the name to Rose-Hulman. The aircraft uses four lift motors for vertical flight and a rear pusher for its planned fixed-wing cruise mode.
The July 21 proof flight demonstrated autonomous VTOL waypoint flight in the proof-flight configuration.
Vehicle overview
MeadowHawk Vehicle Overview
Four motors handle vertical takeoff, hover, and landing. A fifth motor at the rear provides cruise thrust. The design combines runway-independent operation with the goal of retaining fixed-wing cruise efficiency.
The physical carbon structure remains H-shaped. ArduPilot's X-frame allocation matches the installed motor positions.
Approximately 19 lb was the aircraft weight used for the Technical Design Report design condition.
Three 22.2 V packs operate in parallel as one shared electrical system for lift, cruise, avionics, and mission hardware.
ArduPilot on the Pixhawk handles stabilization, navigation, flight modes, and recovery behavior.
Python software on the Jetson runs mission state and perception while the Pixhawk retains the flight-control loop.
The ground crew uses Mission Planner for planning, telemetry, mode supervision, and flight-log review.
The 2026 competition mission combines search, target location, and relief delivery.
Competition mission
Competition Mission Sequence
The planned competition mission ties together autonomous flight, a camera search, target location, and payload delivery, with the ground station and safety pilot supervising the aircraft.
- 01Vertical takeoff
Launch and climb under QuadPlane VTOL control.
- 02Autonomous navigation
Follow the planned waypoint route under safety-pilot supervision.
- 03Search and mapping
Enter the assigned area and collect mission imagery.
- 04Target detection
Process imagery and estimate the target's location.
- 05Payload delivery
Navigate to the delivery point and command the selected release.
- 06Return and landing
Return home and recover in vertical flight.
System overview
Aircraft Systems
Airframe, propulsion, flight controls, mission software, camera, communications, and payload work all affect one another, so the team develops them as parts of the same aircraft.
Airframe and structure
The wing, fuselage, tail, lift booms, and landing gear have to be light enough to fly and sturdy enough for field use.
Propulsion and power
Separate lift and cruise motors share the battery system but serve different parts of the flight.
Flight control and navigation
The Pixhawk stabilizes the aircraft, follows the flight plan, and manages flight modes and recovery behavior.
Mission computing and perception
Python software on the Jetson handles mission state, camera frames, and the detection pipeline.
Communications and ground station
Independent pilot-control and telemetry links keep manual takeover separate from mission supervision.
Payload system
The payload bay, release hardware, and delivery procedure are tested separately before full mission integration.
Risk reduction
Multirotor Experiment Platform
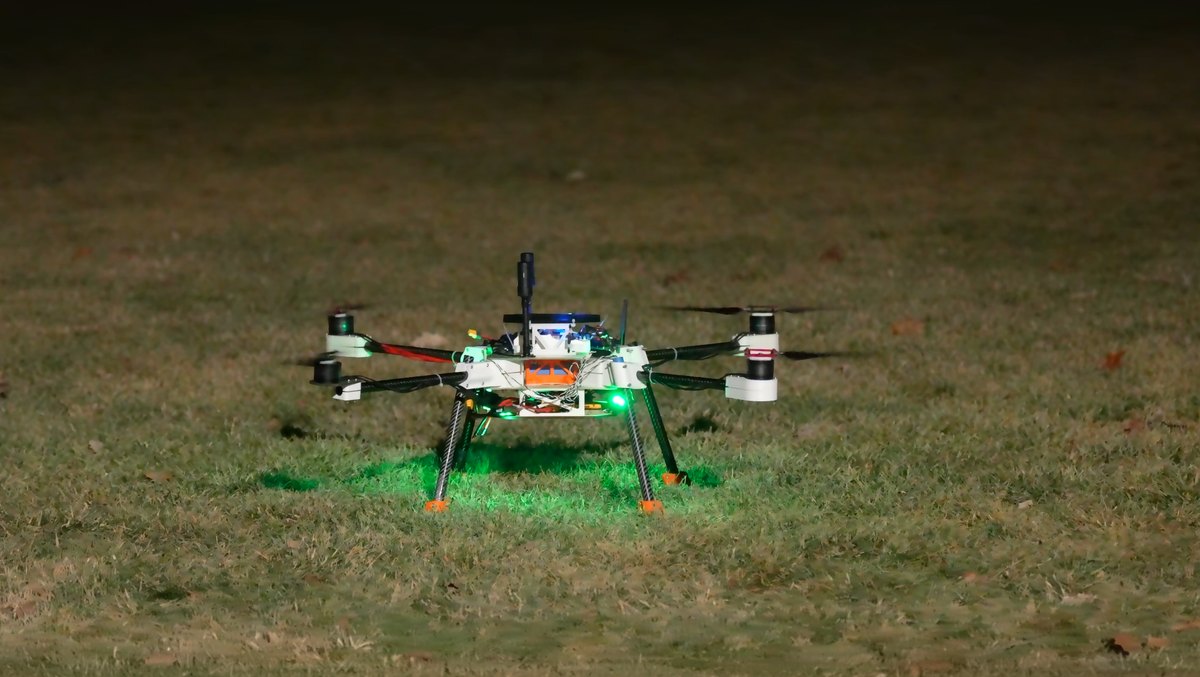
While MeadowHawk was still being built, we used the Multirotor Experiment Platform (MEP) to fly the Pixhawk and Jetson, collect camera data, test communications, and work on the payload mechanism.
- Competition-altitude image collection
- Payload release and deployment tests
- Autonomous flight modes and waypoint missions
- Camera and companion-computer integration
Rose Aerial Systems
Student Engineering Team
Students from across Rose-Hulman design parts, manufacture the airframe, wire avionics, write mission software, and run field tests. The work also includes schedules, documentation, and competition operations.